


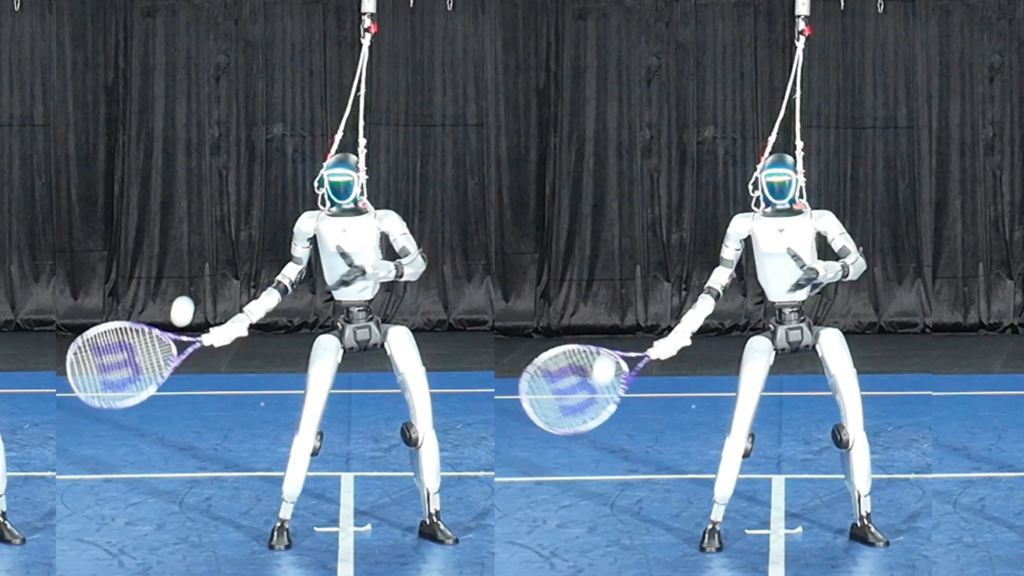
Towards Professional Tennis Styles for Humanoid Robots with Adaptive Motion Planning and Tracking
Towards Professional Tennis Styles for Humanoid Robots with Adaptive Motion Planning and Tracking
Towards Professional Tennis Styles for Humanoid Robots with Adaptive Motion Planning and Tracking
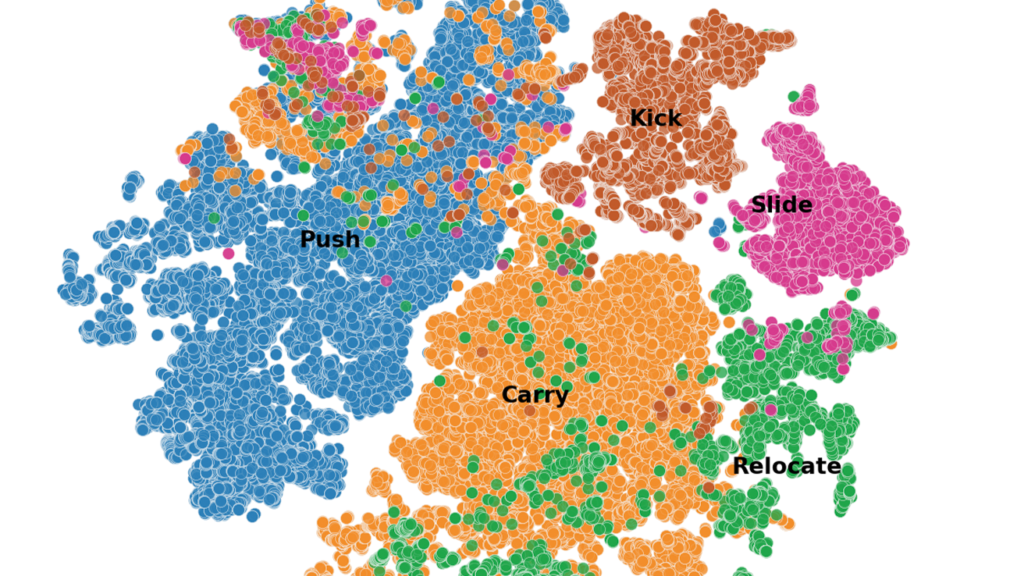
OmniContact: Chaining Meta-Skills via Contact Flow for Generalizable Humanoid Loco-Manipulation
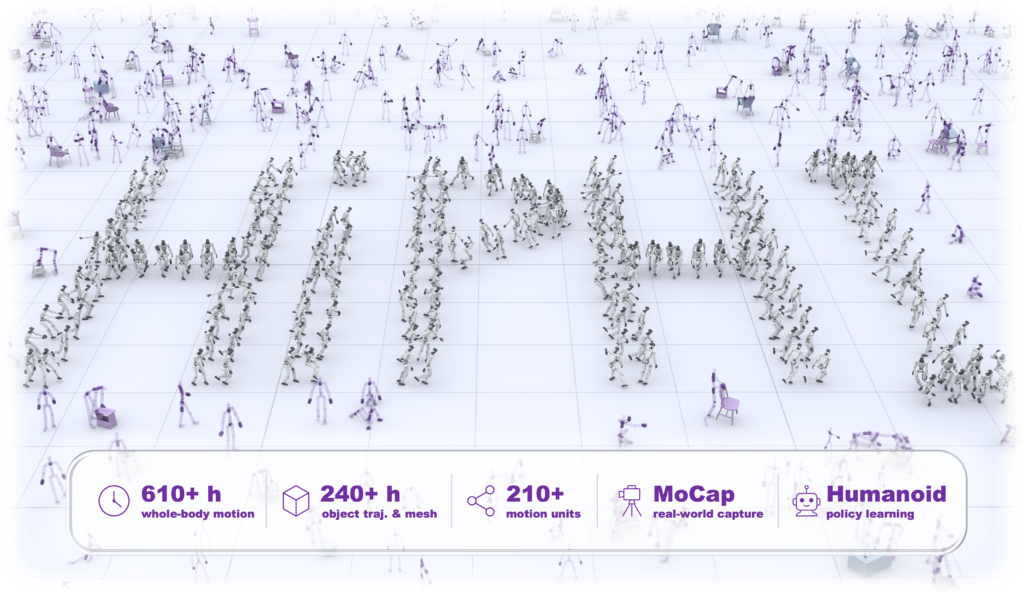
Humanoid intelligence requires learning over an extremely diverse space of whole-body motions and physically grounded interactions. However, existing embodied datasets remain fundamentally limited: internet-scale video data lack precise physical states and interaction grounding, while…